Xiaoyi LinGraduate Student
Wuhan University |
![]() |
I am a first-year graduate student at Wuhan University, majoring in Artificial Intelligence at the School of Computer Science, supervised by Prof. Miao Li. I completed my undergraduate studies in Computer Science at the Hongyi Honor School with a GPA of 3.87/4.00, ranking 15th out of 129 students. I have a cross-disciplinary background, having won a bronze medal in the 37th National Physics Olympiad and a provincial first prize in the National Biology Olympiad.
My research interests include Hand-Object Interaction (HOI) tracking, dexterous manipulation, reinforcement learning, and embodied AI. I focus on advancing frameworks that bridge perception, planning, and control in robotics. I have experience in developing scalable frameworks for synthesizing manipulation trajectories and implementing reinforcement learning-based tracking controllers.
I am actively seeking PhD opportunities and collaborations.
|
Wuhan University, China Master of Engineering in Artificial Intelligence School of Computer Science Advisor: Prof. Miao Li Sep. 2025 - Present |
|
Wuhan University, China Bachelor of Engineering in Computer Science Hongyi Honor School GPA: 3.87/4.00, Ranking: 15/129 Sep. 2021 - Jun. 2025 |
|
BrainCo Research Intern Jun. 2026 - Present Current research appointment. |
|
Noitom Robotics Research Intern, Shenzhen, China Dec. 2025 - Jun. 2026 Closely worked with Runyi Yu. Topic: Humanoid Loco-Manipulation |
|
Zhejiang University CAD&CG Lab Research Intern, Hangzhou, China Jul. 2025 - Sep. 2025 Supervised by Haochen. Topic: Hierarchical VLA system for dual-arm manipulation with grippers |
|
NUS Lin's Lab Research Intern, Singapore Jul. 2024 - Oct. 2024 Supervised by Lin Shao. Topic: Collision avoidance for dexterous hand manipulation |
|
OmniContact: Chaining Meta-Skills via Contact Flow for Generalizable Humanoid Loco-Manipulation Accepted to CoRL 2026Runyi Yu*, Xiaoyi Lin*, Ji Ma, Yinhuai Wang, Koukou Luo, Jiahao Ji, Huayi Wang, Wenjia Wang, Runhan Zhang, Ping Tan, Ting Wu, Ruoli Dai, Qifeng Chen, Lei Han [arXiv] [project page] [code] [dataset] [live demo] |
|
|
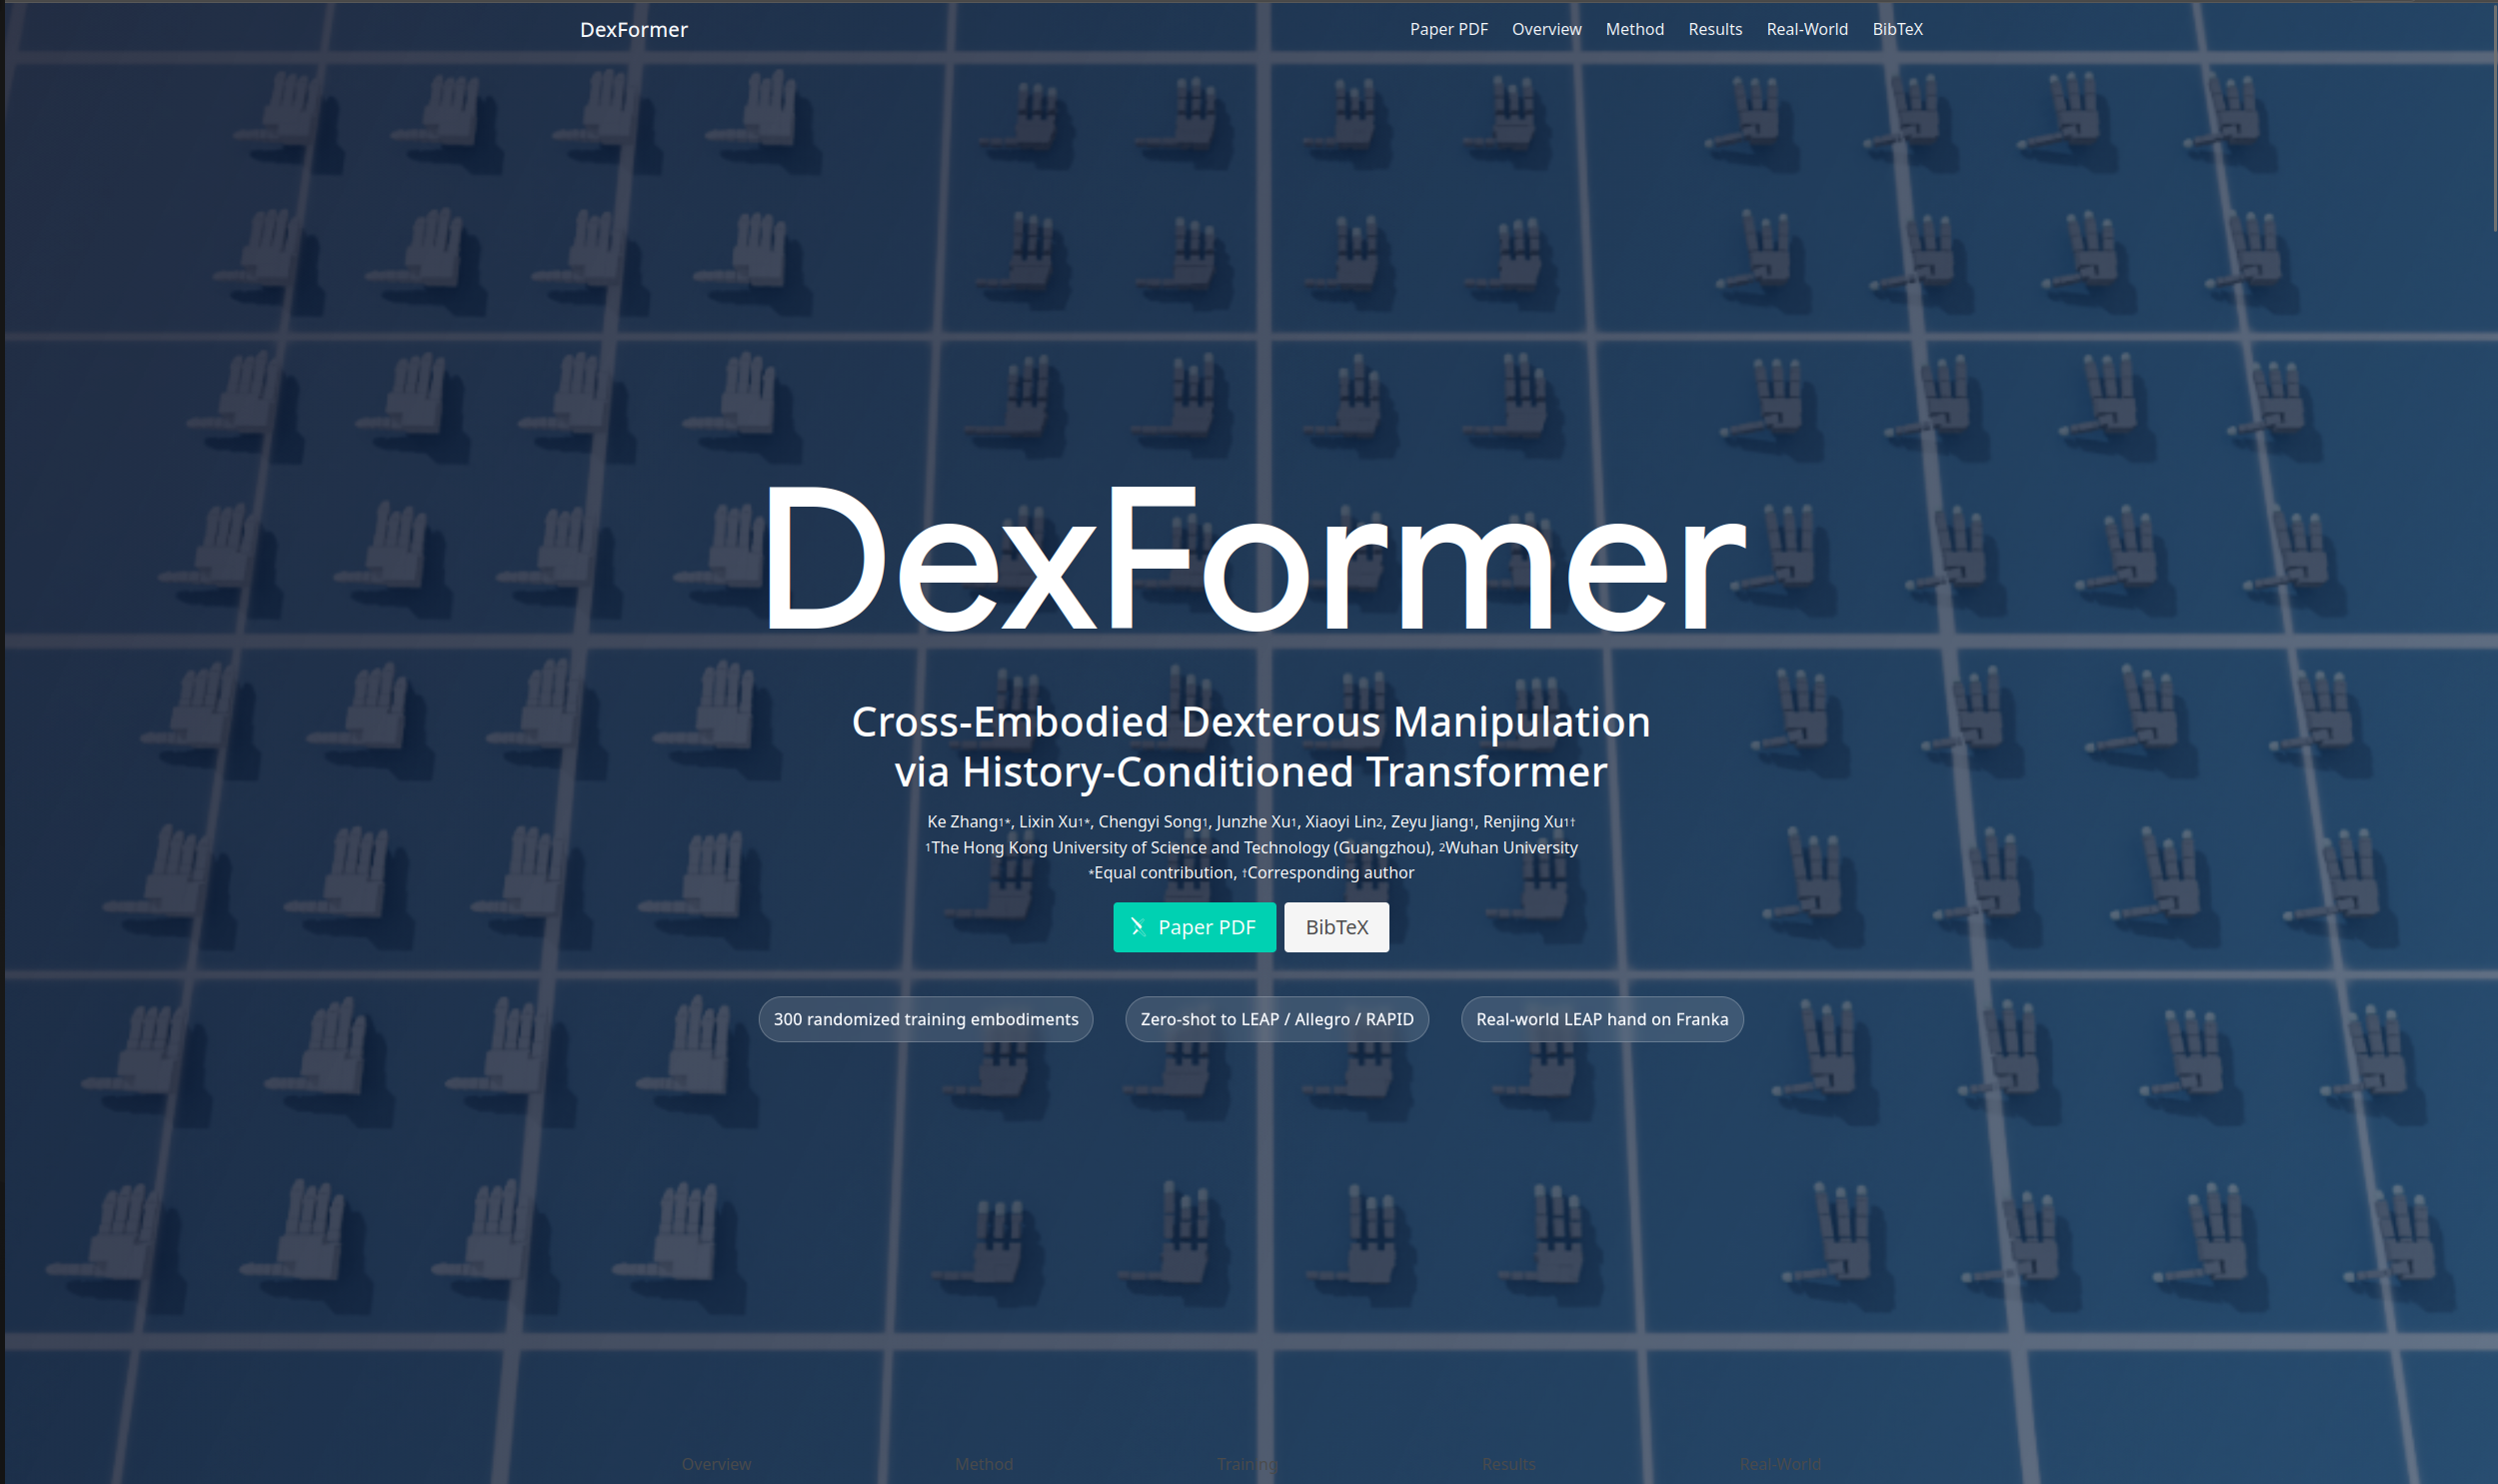
DexFormer: Learning Dexterous Manipulation via Hierarchical Transformers Preprint ArxivKe Zhang*, Lixin Xu*, Chengyi Song, Junzhe Xu, Xiaoyi Lin, Zeyu Jiang, Renjing Xu [arXiv] [project page] [code] |
|
HOT: Learning Generalizable Hand-Object Tracking without Human Demonstration Accepted to NeurIPS 2026Runyi Yu*, Xiaoyi Lin*, Hok Wai Tsui* ,Yinhuai Wang*, Hui Zhang, Qihan Zhao, Ke Fan, Miao Li, Jie Song, Jingbo Wang, Qifeng Chen, Ping Tan [paper] [project page] [code] |
|
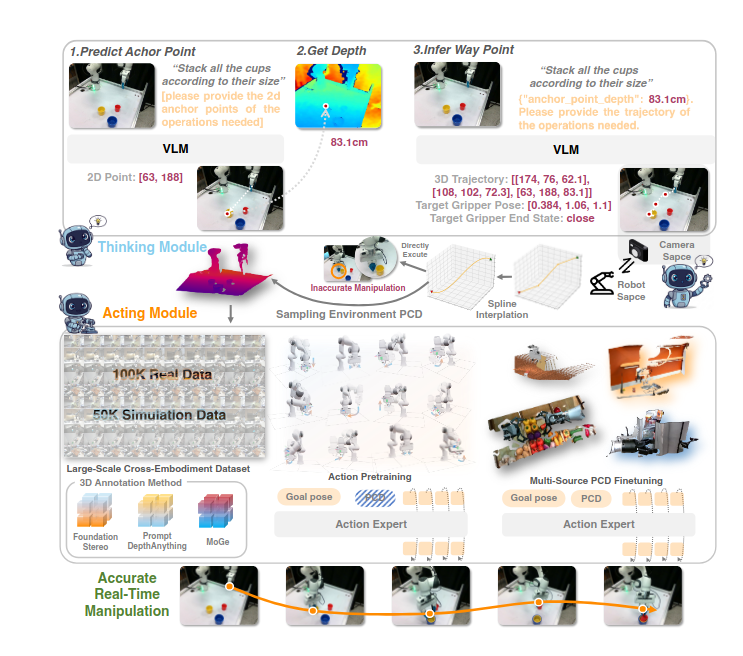
GAE: Unleashing Physical Potential of VLM with Generalizable Action Expert Accepted to ICML 2026Mingyu Liu, Zheng Huang, Xiaoyi Lin, Muzhi Zhu, Canyu Zhao, Zongze Du, Yating Wang, Haoyi Zhu, Hao Chen, Chunhua Shen [arXiv] |
|
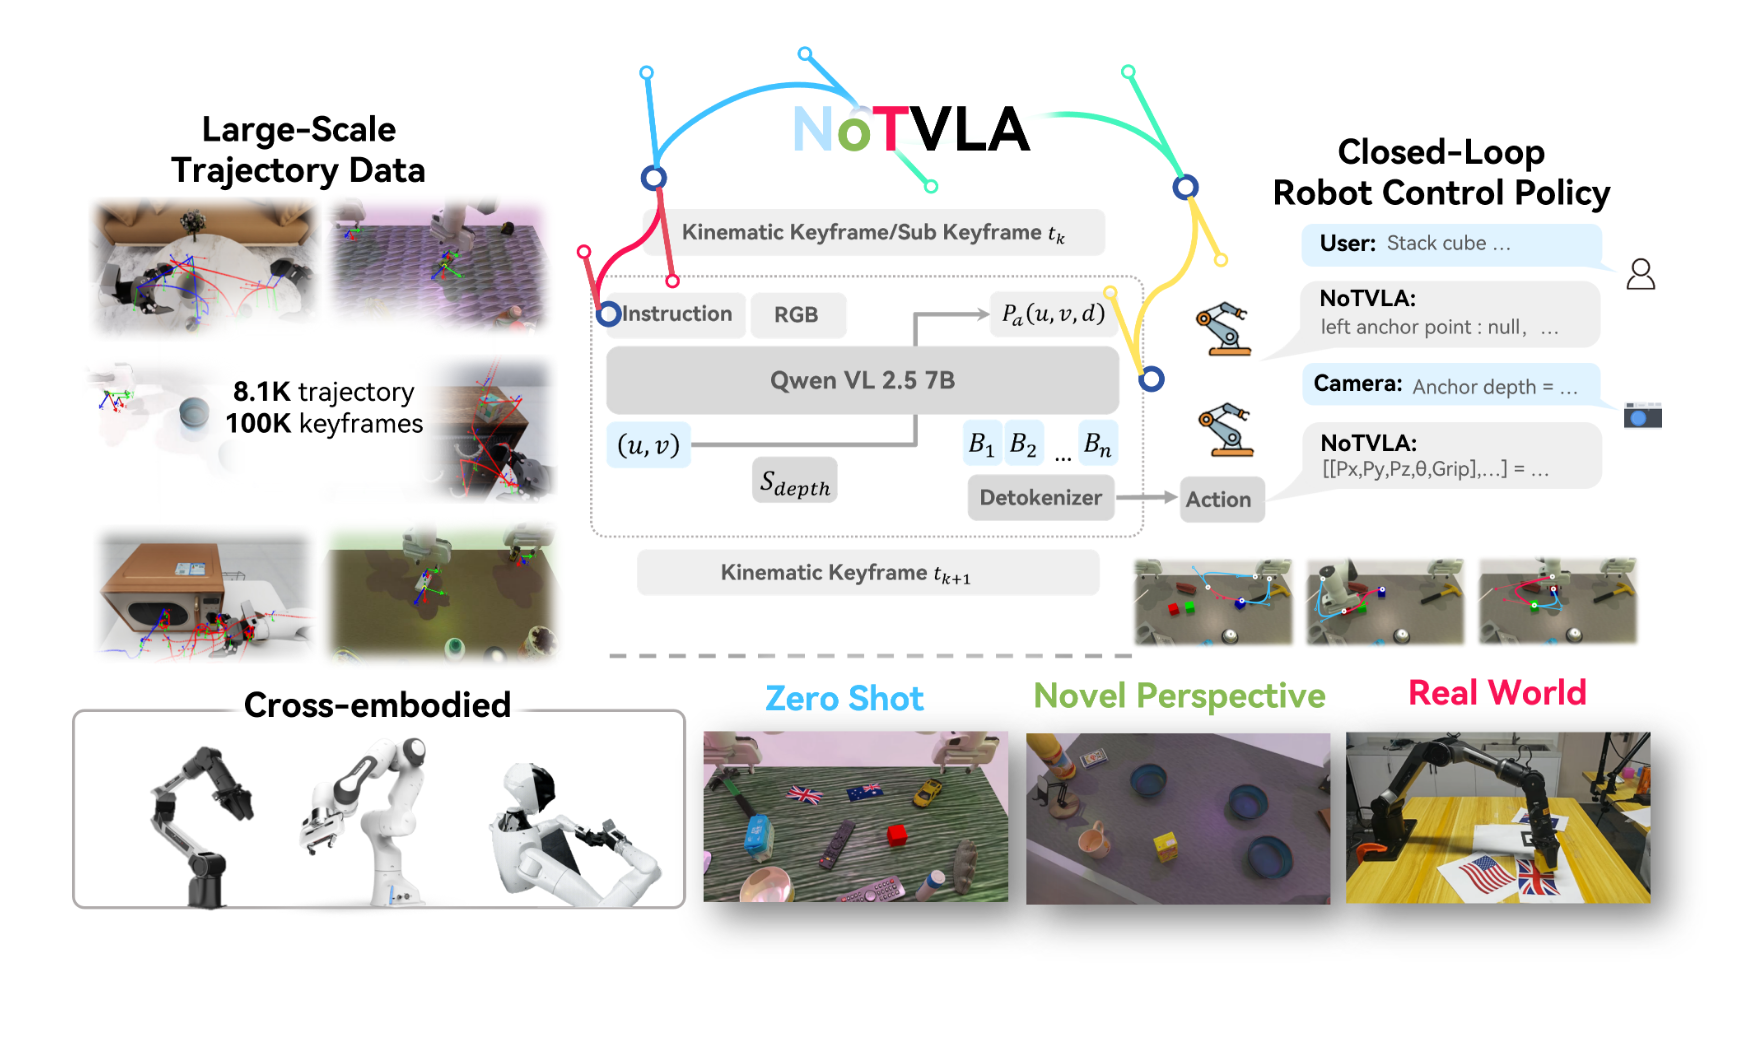
NoTVLA: Narrowing of Dense Action Trajectories for Generalizable Robot Manipulation Accepted to NeurIPS 2026Zheng Huang, Mingyu Liu, Xiaoyi Lin, Muzhi Zhu, Canyu Zhao, Zongze Du, Xiaoman Li, Yiduo Jia, Hao Zhong, Hao Chen, Chunhua Shen [arXiv] |
|
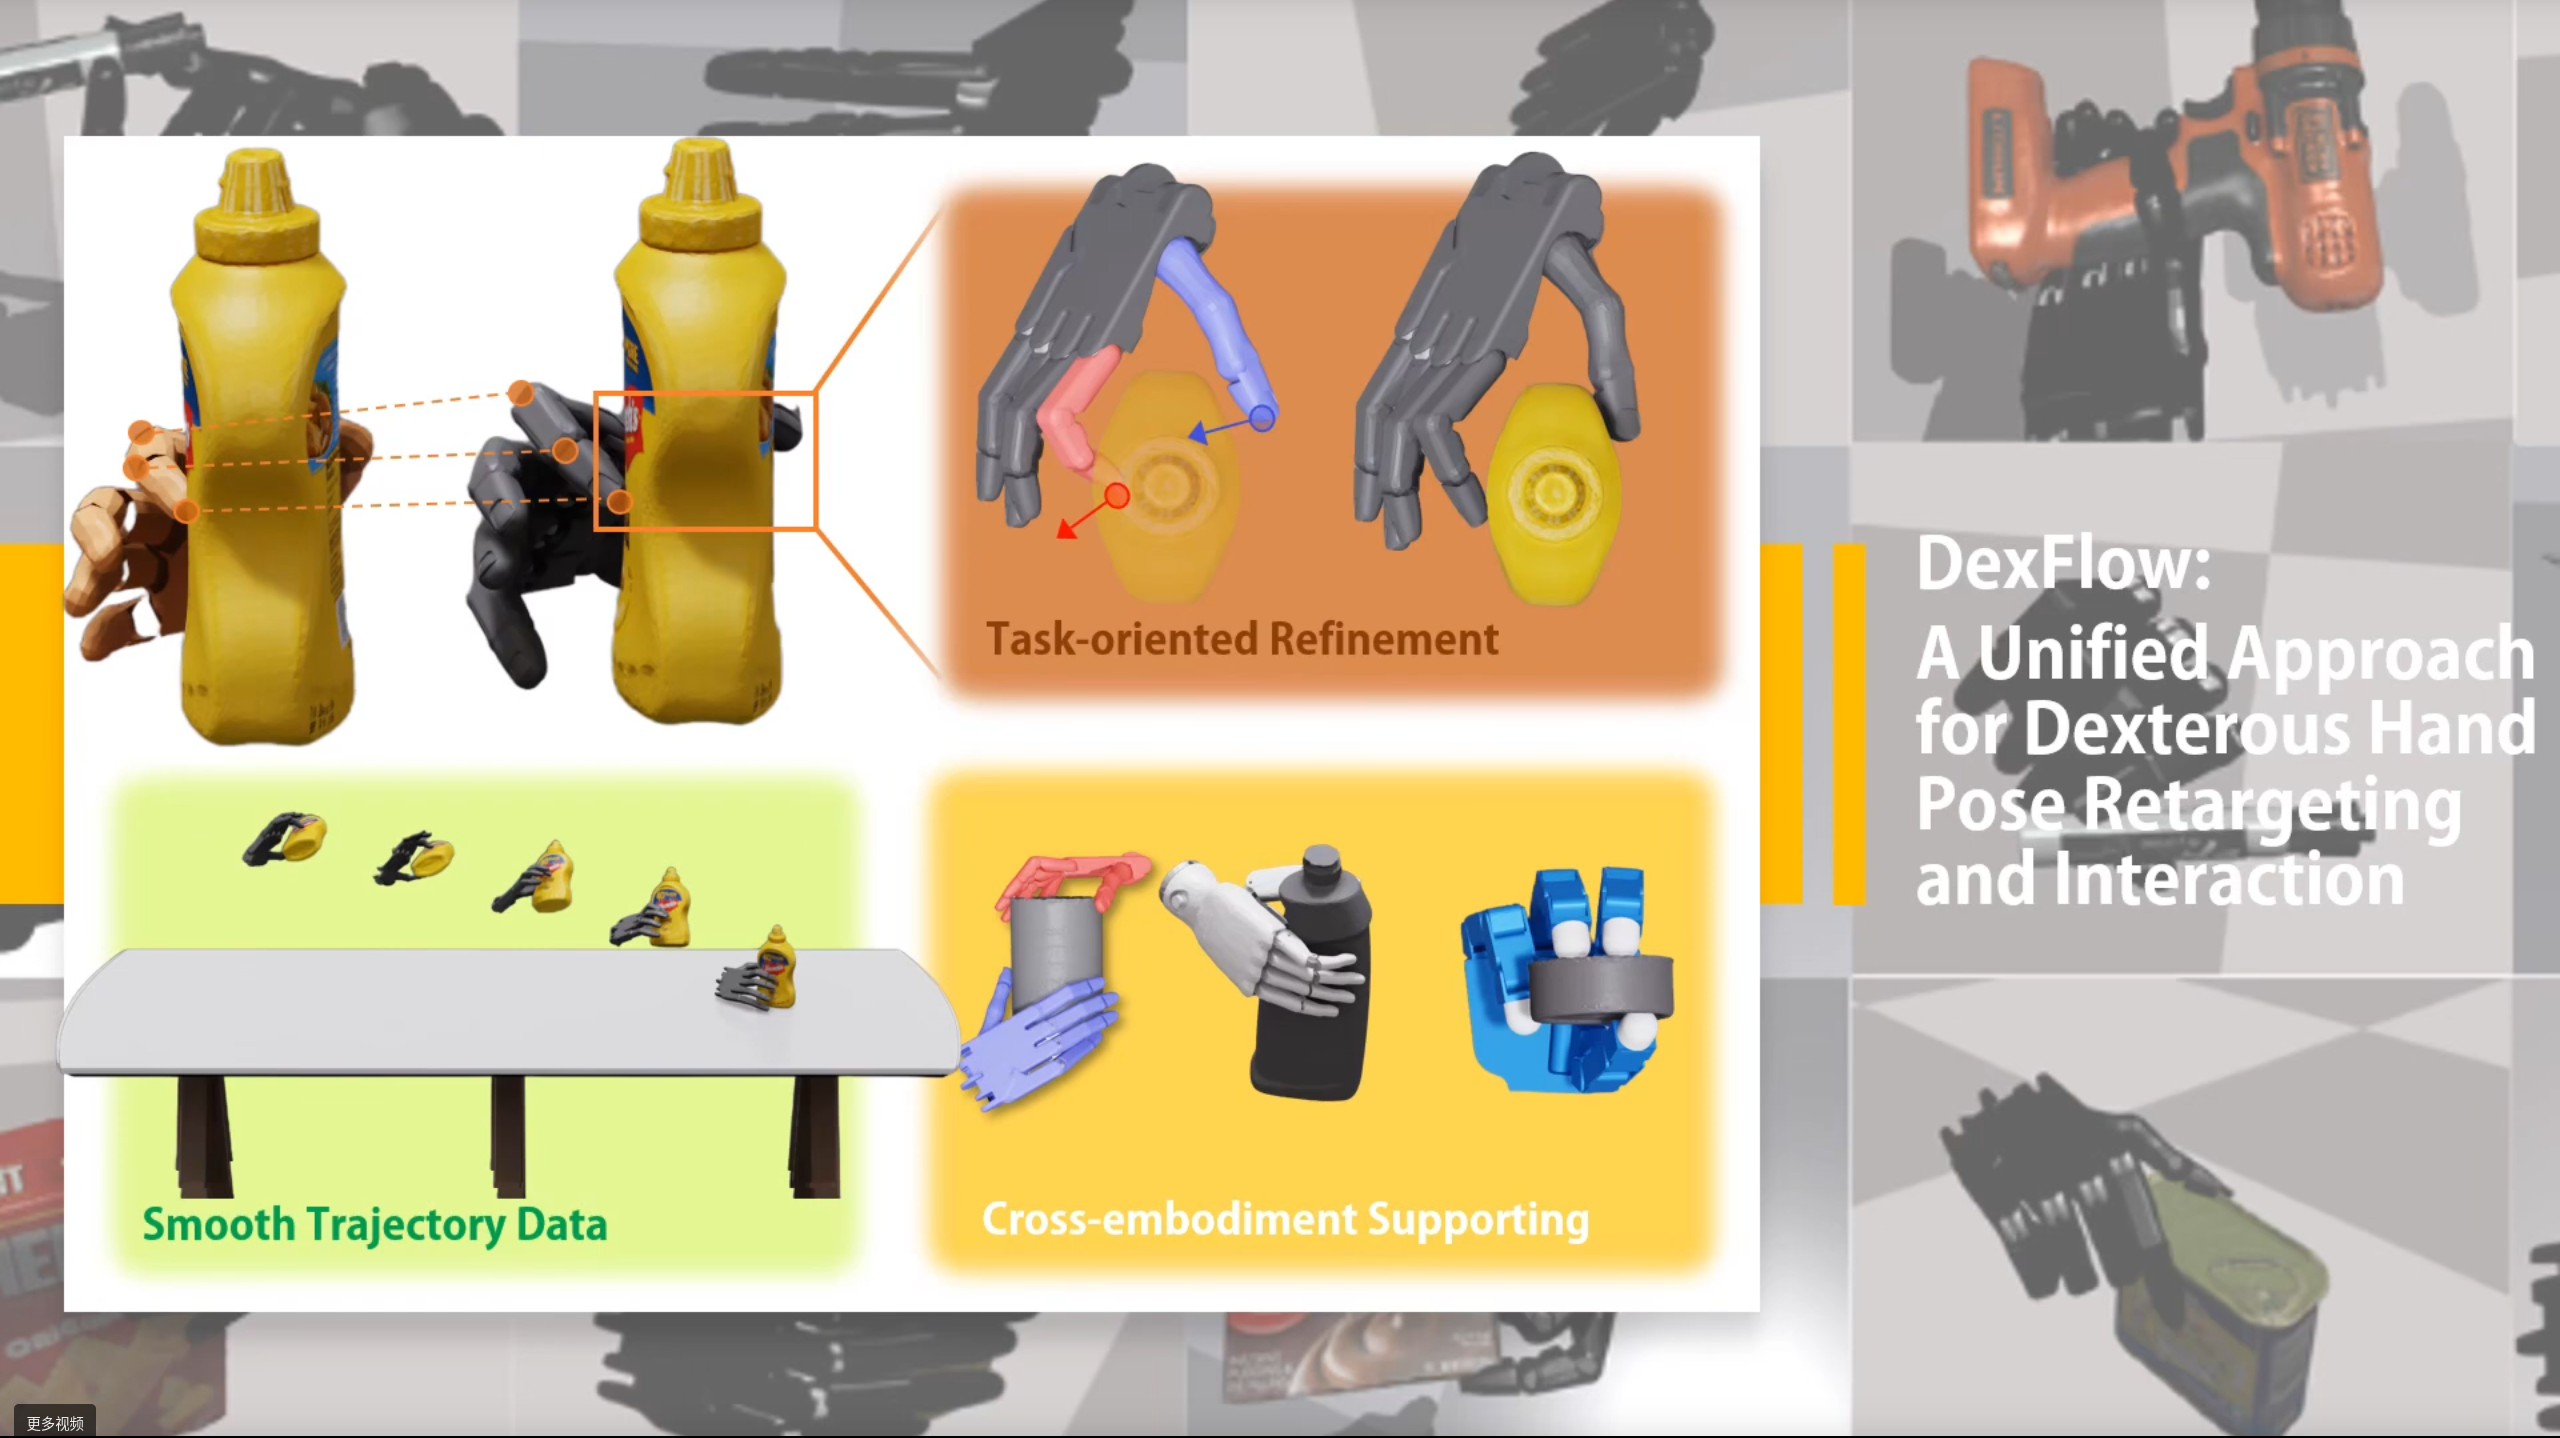
DexFlow: Unified Framework for Dexterous Manipulation Preprint ArxivXiaoyi Lin, Kunpeng Yao, Lixin Xu, Xueqiang Wang, Xuetao Li, Yuchen Wang, Miao Li [arXiv] [project page] |